

The use case tracker showcases the successful adoption and the diverse potential applications of PREEMPT_RT across various industries. Submit your use case today—whether PREEMPT_RT is currently in active use or under evaluation—to gain visibility and contribute to our expanding educational repository.
KEB Automation KG
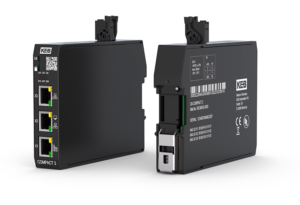
Realtime Motion Control – Embedded Automation Device
Realtime Linux is used on an Embedded Automation Device with Realtime Focus on Control Applications. Industrial Ethernet Protocols used are ETHERCAT (Master) and perhaps PROFINET in the future. The Hardware itself would be capable as EtherCAT Slave as well (Not sure if this Use Case would be possible with Linux…).
Sector or Industry: Industrial Automation, Manufacturing
Status: In Production
Website
https://www.keb-automation.com/de/produkte/steuerungstechnik-automatisierung/embedded-automation-controller/c6-compact-3
Scaling Battery Test Systems to Megawatt Levels with PREEMPT_RT Linux
Keysight Technologies
Scaling Battery Test Systems to Megawatt Levels with PREEMPT_RT Linux
High-power battery testing at the megawatt scale requires deterministic control, fast safety response, and efficient power management. We use PREEMPT_RT Linux in the SL1770A Series Scienlab Power Allocation Management Solution to meet 1 ms control and safety requirements for battery pack and module testing applications.
The SL1770A is a centralized battery test system that provides large-scale testing capabilities in demanding high-power environments, with flexible power allocation to individual test channels. It enables testing at megawatt power levels while keeping grid load manageable through demand-based power allocation.
The system is based on a PCIe FPGA card integrated into a 2U off-the-shelf Xeon server platform. The server communicates via custom fiber-optic links with FPGA-based power electronics, enabling coordination of up to 128 power stages at 100 kW each. Current and voltage measurements are acquired at rates of up to 100 kHz per test channel.
PREEMPT_RT Linux runs on the host server to provide deterministic real-time control of the test bench. The implementation uses standard Linux tooling, drivers, and development workflows.
Sector or Industry: Automotive incl. Assisted Driving
Status: In Production
Website
https://www.keysight.com/us/en/product/SL1770A/power-allocation-management-solution-for-battery-testing.html
Phoenix Contact GmbH & Co. KG
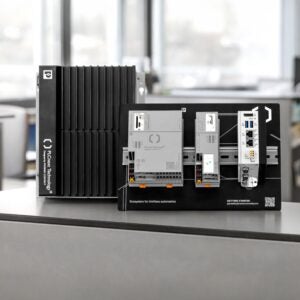
PLCnext Control
PLCnext Control by Phoenix Contact is an industrial controller platform that leverages PREEMPT_RT to combine deterministic real-time automation with the openness of Linux.
The controllers are used in machine and plant automation, where reliable execution of control logic and industrial communication must coexist with modern software workloads, connectivity solutions, and customer-specific applications.
By building on PREEMPT_RT, PLCnext Control provides a foundation for low-latency and predictable system behavior while opening access to the extensive Linux ecosystem and technologies like containerization. This demonstrates how Real-Time Linux can be successfully adopted in commercially available industrial automation products, enabling innovation without sacrificing the real-time requirements essential for industrial control systems.
Sector or Industry: Industrial Automation
Status: In Production
Website
https://www.plcnext-community.net/about-plcnext-technology/plcnext-control/
Qualcomm
Mixed-Criticality Industrial Control Demo with PREEMPT_RT
At Embedded World, Qualcomm Technologies showcased a mixed-criticality industrial automation demo running on the Qualcomm Dragonwing™ IQ9 Series. The demonstration showed how the Dragonwing IQ-9075 processor simultaneously executed deterministic real-time control workloads and rich HMI applications through the combination of Real-Time Linux, PREEMPT_RT, and KVM virtualization.
The real-time domain ran a CODESYS-based PLC application and EtherCAT Master controlling four EtherCAT devices, including motor and sensor interfaces. The application operated on dedicated CPU cores optimized for deterministic execution using PREEMPT_RT and real-time system tuning.
In parallel, a Windows-based HMI was executed inside a virtual machine using KVM and VirtIO. Communication between the PLC and HMI was implemented through OPC UA, while Qt provided a modern graphical user interface. This architecture demonstrated how industrial control, fieldbus communication, and user-facing applications can coexist on a single SoC without requiring separate processors.
The Dragonwing IQ9 platform consolidate traditionally separate PLC, HMI, and computing functions while maintaining real-time determinism. It serves as a blueprint for next-generation industrial PCs, soft PLCs, machine controllers, robotics platforms, and edge AI systems that require both hard real-time control and high-performance application processing.
Sector or Industry: Industrial Automation
Status: Proof of Concept
Qualcomm
How acontis Delivers Sub-Millisecond EtherCAT Control for Physical AI on Qualcomm Dragonwing™ Processors
Qualcomm
How acontis Delivers Sub-Millisecond EtherCAT Control for Physical AI on Qualcomm Dragonwing™ Processors
This demonstration shows how a single Qualcomm Dragonwing™ IQ-9075 running Linux with PREEMPT_RT can combine deterministic EtherCAT motion control and high-performance AI processing on the same platform. Using the acontis EC Master EtherCAT stack, the system controls EtherCAT-connected drives and I/O with sub-millisecond cycle times.
The live setup demonstrates a key requirement for next-generation robotics and Physical AI systems: translating AI-driven decisions into precise, deterministic motion. PREEMPT_RT provides the real-time foundation that allows EtherCAT communication to maintain sub-8 µs jitter, ensuring predictable control behavior while AI applications continue to utilize the same processor resources.
The result is a consolidated architecture where developers can deploy AI, robotics frameworks, and industrial real-time control on a single SoC without requiring separate controllers. This demonstrates how PREEMPT_RT enables Linux to serve as a practical platform for intelligent robots, AI-enabled PLCs, and other Physical AI applications that demand both advanced compute and deterministic real-time performance.
Sector or Industry: Industrial Automation
Status: Proof of Concept
Siemens Mobility
Real Time linux Kernel for TDMA in Kavach
We are planning to use the RT patch of linux for handling the Real Time needs of India’s ATP(Advanced Train Protection) system – KAVACH (Train Collision Avoidance System). It has defined a TDMA (Time Division Multiple Access) Scheme in which every functional slot is ~22.5 millisecond and then 5 millisecond of guard.
To realize this TDMA scheme we need sub-millisecond level precision, so that tasks can be Scheduled & Executed in expected time slots with tolerance of ~ 200-300 microseconds. This we are trying to achieve using the RT patch of Linux.
Sector or Industry: Automotive incl. Assisted Driving, Industrial Automation, Transportation, Safety Critical ATP system
Status: Proof of Concept
Siemens Mobility
Trackguard Cargo MSR32
Trackguard Cargo MSR32 is a control system for automated shunting yards and marshalling interlockings, managing critical components like wheel sensors and signals across Europe. Originally based on Siemens’ proprietary RMOS, its discontinuation prompted a search for a new real-time operating system. The team chose PREEMPT_RT Linux to preserve the existing MSR32 software, meet strict single-digit millisecond real-time demands, reduce vendor reliance, cut costs, and leverage open-source support and security.
Real-time Linux has delivered substantial advantages. It provides measurable determinism, crucial for system approvals, and broad hardware compatibility, allowing MSR32 to run on standard x86 hardware, simplifying procurement. The extensive Linux toolset significantly aids debugging, and the ability to isolate non-critical services ensures peak real-time performance. Furthermore, PREEMPT_RT’s integration into the mainline kernel guarantees long-term support, securing the system’s future.
Sector or Industry: Transportation
Status: In Production
Website
https://www.mobility.siemens.com/global/en/portfolio/rail-infrastructure/mainline/yard-and-depot-solutions.html
TRUMPF Laser SE
Use of real time Linux in industrial welding lasers
We use real time linux in then control of industrial welding lasers. It is used to drive the fieldbus interfaces to our customers, to do diagnostics and to control the laser.
Sector or Industry: Industrial Automation
Status: In Production
Website
https://www.trumpf.com/en_INT/products/lasers/beam-sources/laser-for-welding/
Weidmüller
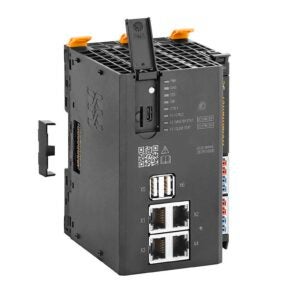
u-OS Linux based Operating System Platform
u‑OS is a Linux-based operating system designed for industrial automation and Industrial IoT (IIoT) applications, built on a Yocto-based Linux distribution with integrated PREEMPT_RT real-time capabilities. It enables deterministic execution of control and data-processing workloads on industrial edge devices, allowing multiple applications—such as PLC runtimes, data analytics, and communication services—to run concurrently while maintaining strict real-time performance requirements.
By leveraging PREEMPT_RT, u‑OS provides predictable low-latency behavior and fine-grained scheduling control, which is essential for industrial use cases such as machine control, fieldbus communication, and high-frequency data exchange. Combined with its container-based application model and open interfaces, u‑OS allows seamless integration of third-party software while ensuring real-time determinism, making it a robust platform for scalable, flexible, and future-proof industrial automation solutions.
Sector or Industry: Industrial Automation
Status: In Production
Website
https://www.weidmueller.com/int/solutions/technologies/edge_computing_u_os/index.jspNo vendors found.